A team of researchers at the University of California San Diego has created a soft robotic skin that enables millimeter-wide vine-like robots to navigate tight and fragile environments.
According to the research team, this development could eventually lead to robotic medical tools that move through the body’s arteries or robotic inspection devices that crawl into machinery.
 Source: University of California San Diego
To develop the robotic skin, the team incorporated a very thin layer of heat and pressure responsive actuators composed of liquid crystal elastomer (LCE) at specific points within the soft skin.
The team explained that by controlling the pressure inside the robot’s body as well as the temperature of the actuators, they were able to steer the skin through intricate paths.
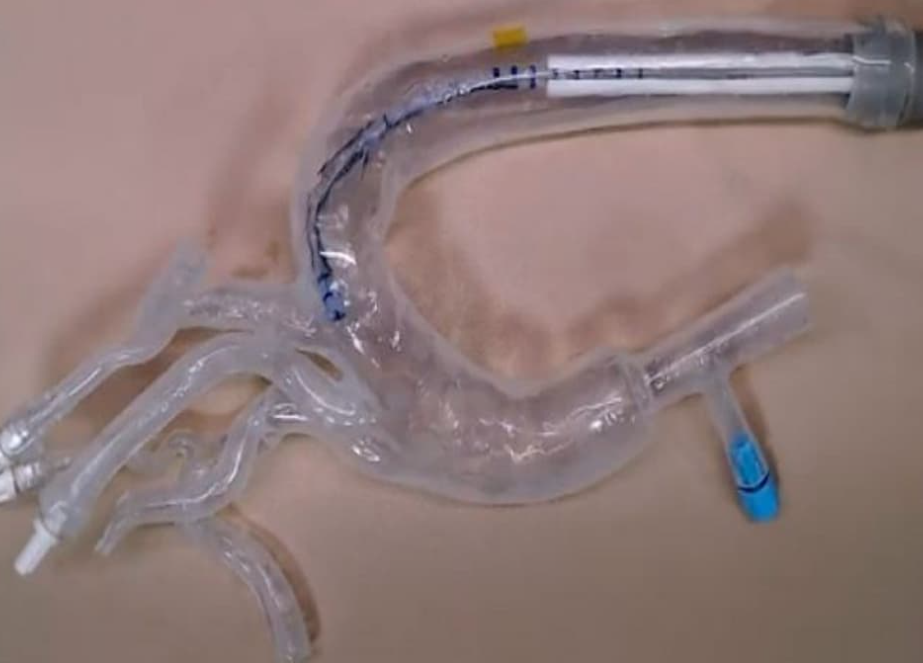
During trials, the team outfitted a robot with the new skin and successfully navigated it through a model of human arteries. During another trial, the robot outfitted with the skin was maneuvered through the interior of a jet engine.
“Our work represents a step toward small, steerable, soft vine robots for applications in delicate and constrained environments,” the team explained.
The robot outfitted with the skin can be steered using temperature, pressure or a combination of both with pressure being the most effective.
“They embedded small, flexible heaters under the actuators to control the actuator’s temperature and built a system to precisely adjust the pressure inside the robot for steering,” the team explained.
The team demonstrated that the robot outfitted with the skin could successfully make multiple turns exceeding 100° along its body length when activated. The robot also managed to squeeze through gaps half its diameter, threading through a human aorta model and a connecting artery.
A tiny camera was also attached to the robot, which enabled it to inspect hard-to-reach spots within a jet engine model, thus proving its potential value in aerospace maintenance and other precision tasks.
“The soft skin developed in this work could further be adapted for other various soft robotic systems, such as wearable haptic devices, soft grippers and locomotive soft robots,” the team concluded.
For more on the robotic skin, watch the accompanying video that appears courtesy of the University of California San Diego.