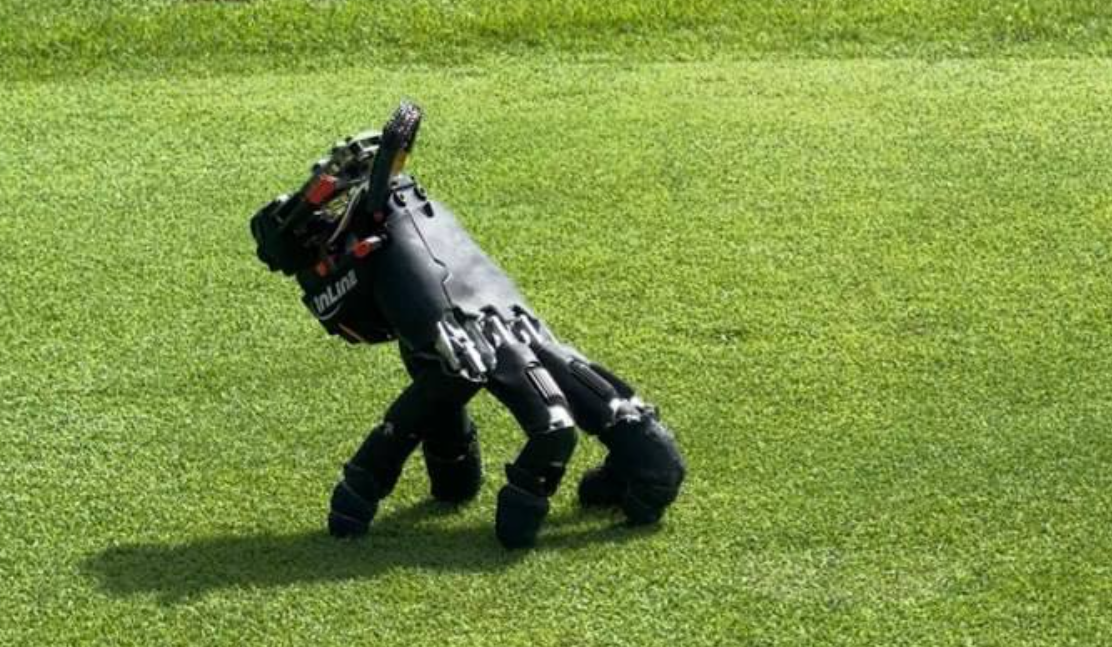
A robotics team at ETH Zurich has developed a module that attaches to a robotic hand and enables it to independently move around using its own fingers in lieu of wheels or legs.
The enhanced robot, appropriately dubbed Fingers as Legs, uses its fingers to traverse assorted surfaces, as well as recovering after falls, moving objects and pressing keys on a keyboard.
 Source: ETH Zurich
This is possible because the robotic hand is equipped with a device that features a power supply, motors, sensors and a computing module, all of which enable it to move autonomously. Further, the robotic hand weighs 818 g and includes 20 active joints.
The hand exhibits the ability to crawl while also performing tasks and interacting with its surroundings, as some fingers serve as supports. So far, the ETH Zurich team has demonstrated the robotic hand on 14 types of surfaces as well as its ability to recover after a fall. Additionally, when tested on a keyboard, the robotic hand pressed sequential keys without visual confirmation, following the operator’s commands.
The team suggests that the robot might be useful in applications where larger robots struggle to operate, such as in confined spaces.
An article detailing the robot, “Fingers as Legs: Learning Self-Supported Locomotion and Manipulation with an Anthropomorphic Hand,” appears in the preprint server arXiv.